Previous
Next
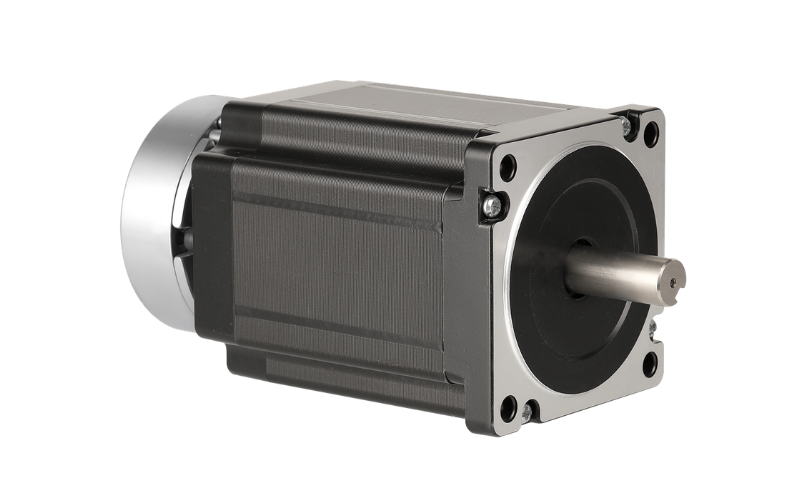
AW86HS Series — NEMA 34 Stepper Motor with Spring Brake
The AW86HS spring brake series is Apexwell's NEMA 34 (86mm) hybrid stepper motor line fitted with an integrated spring-applied holding brake, so the shaft stays locked in position when motor power is removed. Across six body lengths from 68mm to 158mm, motor holding torque scales from 2.7 N·m to 11.0 N·m, and each model is available in either 4-wire (bipolar) or 6-wire (center-tap) configuration. The brake adds approximately 37.5mm to the motor's overall length.
Shared Specifications (all models)
| Parameter | Value |
|---|---|
| Step Angle | 1.8° |
| Step Accuracy | ±5% |
| Lead Wire Configuration | 4-wire (bipolar) or 6-wire (center-tap) |
| Brake Type | Spring-applied holding brake |
| Insulation Class | Class B (130°C) |
| Temperature Rise | 50K Max |
| Ambient Temperature | -20°C to +50°C |
| Insulation Resistance | ≥100 MΩ (500 VDC) |
| Dielectric Strength | 500 VAC, 1 minute |
Motor Model Comparison
| Model | Body Length | Phase Current | Phase Resistance | Phase Inductance | Holding Torque | Rotor Inertia | Mass |
|---|---|---|---|---|---|---|---|
| AW86HSA68-4004A | 68 mm | 4.0 A | 0.63 Ω | 3.2 mH | 2.7 N·m | 1,574 g·cm² | 1.85 kg |
| AW86HSA80-5004A | 80 mm | 5.0 A | 0.38 Ω | 3.5 mH | 4.5 N·m | 2,120 g·cm² | 2.50 kg |
| AW86HSA98-6004A | 98 mm | 6.0 A | 0.50 Ω | 5.0 mH | 5.2 N·m | 3,110 g·cm² | 3.10 kg |
| AW86HSA118-6004A | 118 mm | 6.0 A | 0.60 Ω | 6.8 mH | 8.5 N·m | 3,970 g·cm² | 3.75 kg |
| AW86HSA128-5004A | 128 mm | 5.0 A | 0.60 Ω | 7.0 mH | 9.0 N·m | 4,540 g·cm² | 4.25 kg |
| AW86HSA158-6004A | 158 mm | 6.0 A | 0.73 Ω | 8.0 mH | 11.0 N·m | 5,820 g·cm² | 5.20 kg |
Brake Specifications
| Parameter | Value |
|---|---|
| Static Friction Torque | 4.0 N·m |
| Rated Voltage | DC 24V ±10% |
| Rated Power | 9.2 W |
| Current | 0.585 A |
| Resistance | 62.3 Ω |
| Pull-in Voltage | 20V Max |
| Dielectric Strength | 500 VAC / 1s, 2mA |
The brake holds the motor shaft via spring force when de-energized and releases when 24VDC is applied to the brake coil, independent of the motor phase windings.
Wiring
Each AW86HS motor is available in either 4-wire (bipolar) or 6-wire (center-tap) configuration, so it can drop into either a bipolar or unipolar driver setup without a different motor SKU. The brake coil is wired and powered separately from the motor phases.
Typical Applications
With a 4.0 N·m spring-applied holding brake on a NEMA 34 footprint, the AW86HS spring-brake series fits vertical (Z-axis) industrial drives, robotic joints that must hold position when power is removed, lift and hoist mechanisms, and other applications where an unpowered axis must not drift or fall under load.
Why Choose the AW86HS Spring Brake Series
A spring-applied brake keeps the shaft locked whenever the motor is de-energized — whether from a planned power-down or an unplanned fault — which a plain stepper's holding torque alone cannot guarantee once current is removed. This design's spring-engaged mechanism is a common choice where a specific pull-in voltage and dielectric rating need to be verified against a customer's safety spec. Six body lengths let a product line scale motor holding torque roughly 4x (2.7–11.0 N·m) without changing the mounting footprint. For higher brake holding torque on the same frame, see the AW86HS permanent magnet brake series. Custom brake torque and connector configurations are available on request.
We can customize the electrical parameters of the motor and geometric dimensions such as the motor output shaft size according to customer requirements. Accessories including pulleys, eccentric gearboxes, planetary gearboxes and encoders can also be added. For more products and detailed specifications, please download the product catalog from the Download Center.