Previous
Next
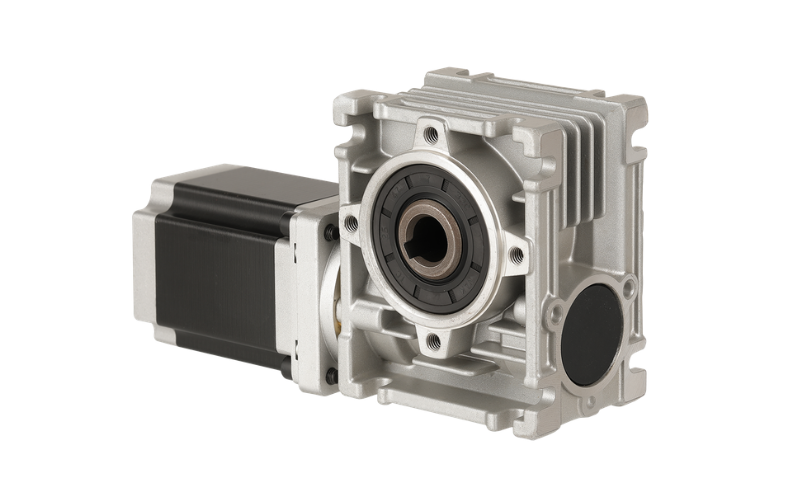
AW60HS Series — NEMA 24 Stepper Motor with Worm Reduction Gearbox
The AW60HS series pairs Apexwell's NEMA 24 (60mm), 1.8° hybrid stepper motor with an NMRV040 worm reduction gearbox, scaling motor holding torque from 1.25 N·m to 2.8 N·m across four body lengths. With reduction ratios from 7.5:1 to 100:1 and a fixed 40 N·m maximum permissible torque, this series delivers more than 2.5x the gearbox torque capacity of the AW57HS worm-gear line from the same right-angle NMRV platform.
Shared Specifications (all models)
| Parameter | Value |
|---|---|
| Step Angle | 1.8° |
| Step Accuracy | ±5% |
| Lead Wire Configuration | 4-wire (bipolar) or 6-wire (center-tap) |
| Insulation Class | Class B (130°C) |
| Temperature Rise | 50K Max |
| Ambient Temperature | -20°C to +50°C |
| Insulation Resistance | ≥100 MΩ (500 VDC) |
| Dielectric Strength | 500 VAC, 1 minute |
| Gearbox Type | NMRV040 worm reduction gearbox |
| Reduction Ratio Range | 7.5:1 to 100:1 |
| Output Configuration | Right-angle (90°) output shaft |
Motor Model Comparison
| Model | Body Length | Phase Current | Phase Resistance | Phase Inductance | Holding Torque | Rotor Inertia | Mass |
|---|---|---|---|---|---|---|---|
| AW60HS56-4204A | 56 mm | 4.2 A | 0.40 Ω | 1.6 mH | 1.25 N·m | 478 g·cm² | 0.58 kg |
| AW60HS65-2804A | 65 mm | 2.8 A | 0.95 Ω | 2.5 mH | 1.40 N·m | 590 g·cm² | 0.58 kg |
| AW60HS88-4204A | 88 mm | 4.2 A | 0.85 Ω | 2.8 mH | 2.50 N·m | 987 g·cm² | 1.40 kg |
| AW60HS100-4204A | 100 mm | 4.2 A | 0.80 Ω | 3.0 mH | 2.80 N·m | 1,163 g·cm² | 1.60 kg |
Wiring
Each AW60HS motor is available in either 4-wire (bipolar) or 6-wire (center-tap) configuration, so it can drop into either a bipolar or unipolar driver setup without a different motor SKU.
NMRV040 Worm Reduction Gearbox Specifications
| Parameter | Value |
|---|---|
| Reduction Ratio | 7.5, 10, 15, 20, 25, 30, 40, 50, 60, 80, 100 |
| Gearbox Length (L1) | 120 mm |
| Max Torque Moment | 40 N·m |
| Transmission Efficiency | 60% |
| Weight | 2.3 kg |
Eleven reduction ratios are available (7.5 to 100:1) on a fixed gearbox footprint — max torque moment, length, and weight stay constant across the entire ratio range, so changing ratio doesn't change the mechanical envelope.
Typical Applications
With a right-angle output and gearbox torque up to 40 N·m, the AW60HS worm-gear series fits heavier gate and door actuators, industrial valve and damper drives, lift and tilt mechanisms, and other applications where the AW57HS's torque range isn't enough and the load needs to hold position without continuous motor power.
Why Choose the AW60HS Worm Gearmotor
The right-angle output lets the gearbox change direction in the mechanical layout without an additional bevel or belt stage, and worm gearing at higher reduction ratios typically resists being back-driven by the load — useful in lifting, tilting, or holding applications where position needs to stay put if power is lost, though the exact self-locking threshold depends on load and friction conditions and should be verified for safety-critical uses. Eleven reduction ratios on one fixed-envelope gearbox let torque and output speed be tuned without changing the mounting footprint. Custom shaft configurations and encoder feedback are available on request.
We can customize the electrical parameters of the motor and geometric dimensions such as the motor output shaft size according to customer requirements. Accessories including pulleys, eccentric gearboxes, planetary gearboxes and encoders can also be added. For more products and detailed specifications, please download the product catalog from the Download Center.