Previous
Next
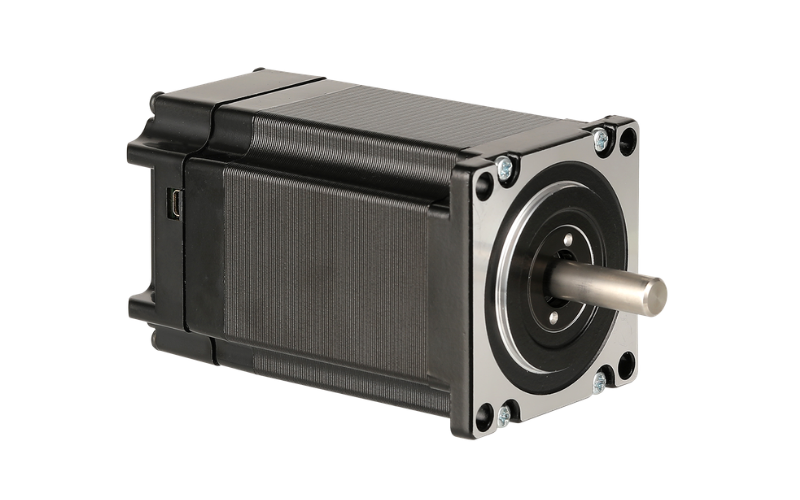
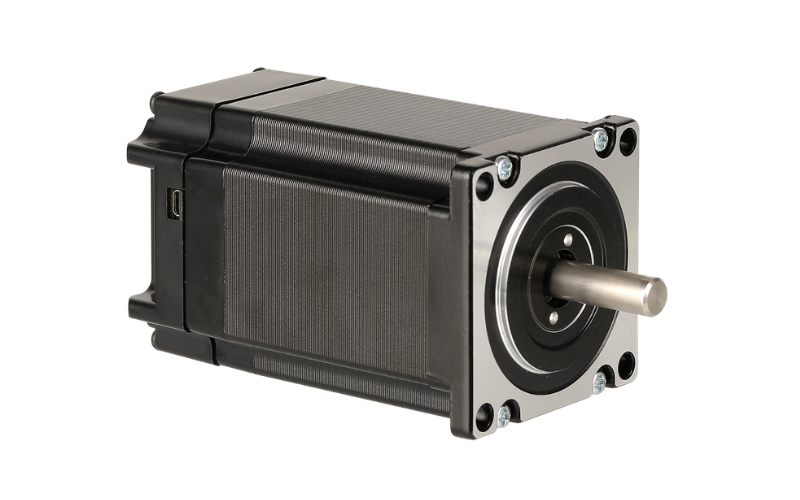
AW57HS Series — NEMA 23 Closed Loop Stepper Motor with Integrated Driver
The AW57HS series is Apexwell's NEMA 23 (57mm) closed loop stepper motor line with the driver, absolute encoder, and control loop built into the motor housing — no external driver required. Across seven body lengths from 41mm to 112mm, holding torque scales from 0.55 N·m to 2.4 N·m, giving designers a high-torque, plug-and-play positioning solution for industrial equipment where panel space and wiring complexity are at a premium.
Shared Specifications (all models)
| Parameter | Value |
|---|---|
| Step Angle | 1.8° |
| Step Accuracy | ±5% |
| Drive Type | Integrated (motor + driver + encoder in one housing) |
| Position Feedback | 15-bit single-turn absolute magnetic encoder + FOC algorithm |
| Control Methods | IO input, Pulse/Direction, PWM duty cycle, RS485 bus, CAN bus |
| Communication Protocol | CANopen standard servo protocol (position, speed, homing control) |
| Insulation Class | Class B (130°C) |
| Temperature Rise | 50K Max |
| Ambient Temperature | -20°C to +50°C |
| Insulation Resistance | ≥100 MΩ (500 VDC) |
| Dielectric Strength | 500 VAC, 1 minute |
| Protection | Overvoltage, undervoltage, overheating, overcurrent |
Model Comparison
| Model | Body Length | Phase Current | Phase Resistance | Phase Inductance | Holding Torque | Rotor Inertia | Mass |
|---|---|---|---|---|---|---|---|
| AW57HS41-2504A | 41 mm | 2.5 A | 1.1 Ω | 2.4 mH | 0.55 N·m | 174 g·cm² | 0.50 kg |
| AW57HS51-2004A | 51 mm | 2.0 A | 1.4 Ω | 4.4 mH | 0.80 N·m | 257 g·cm² | 0.70 kg |
| AW57HS56-4004A | 56 mm | 4.0 A | 0.40 Ω | 1.3 mH | 1.00 N·m | 300 g·cm² | 0.75 kg |
| AW57HS76-4004A | 76 mm | 4.0 A | 0.35 Ω | 1.55 mH | 1.60 N·m | 514 g·cm² | 1.10 kg |
| AW57HS84-4204A | 84 mm | 4.2 A | 0.70 Ω | 2.6 mH | 2.00 N·m | 578 g·cm² | 1.20 kg |
| AW57HS100-4204A | 100 mm | 4.2 A | 0.75 Ω | 3.4 mH | 2.40 N·m | 758 g·cm² | 1.30 kg |
| AW57HS115-4204A | 112 mm | 4.2 A | 0.90 Ω | 3.8 mH | 2.40 N·m | 856 g·cm² | 1.45 kg |
Each model is available in two control variants on the same electrical platform: -IP (pulse/direction input) and -IC (RS485/CAN bus input), sharing identical motor specifications.
Control & Wiring
The AW57HS ships in two connector configurations:
IP (Pulse) type — 10-pin control connector (VCC, GND, PUL+/-, DIR+/-, ENA+/-, ALM+/-) plus a separate 2-pin power connector (+24–48 VDC, GND).
IC (Bus) type (485/CAN) — 10-pin control connector carrying digital I/O plus 485A/485B or CANH/CANL, plus the same 2-pin power connector.
Closed Loop Feedback
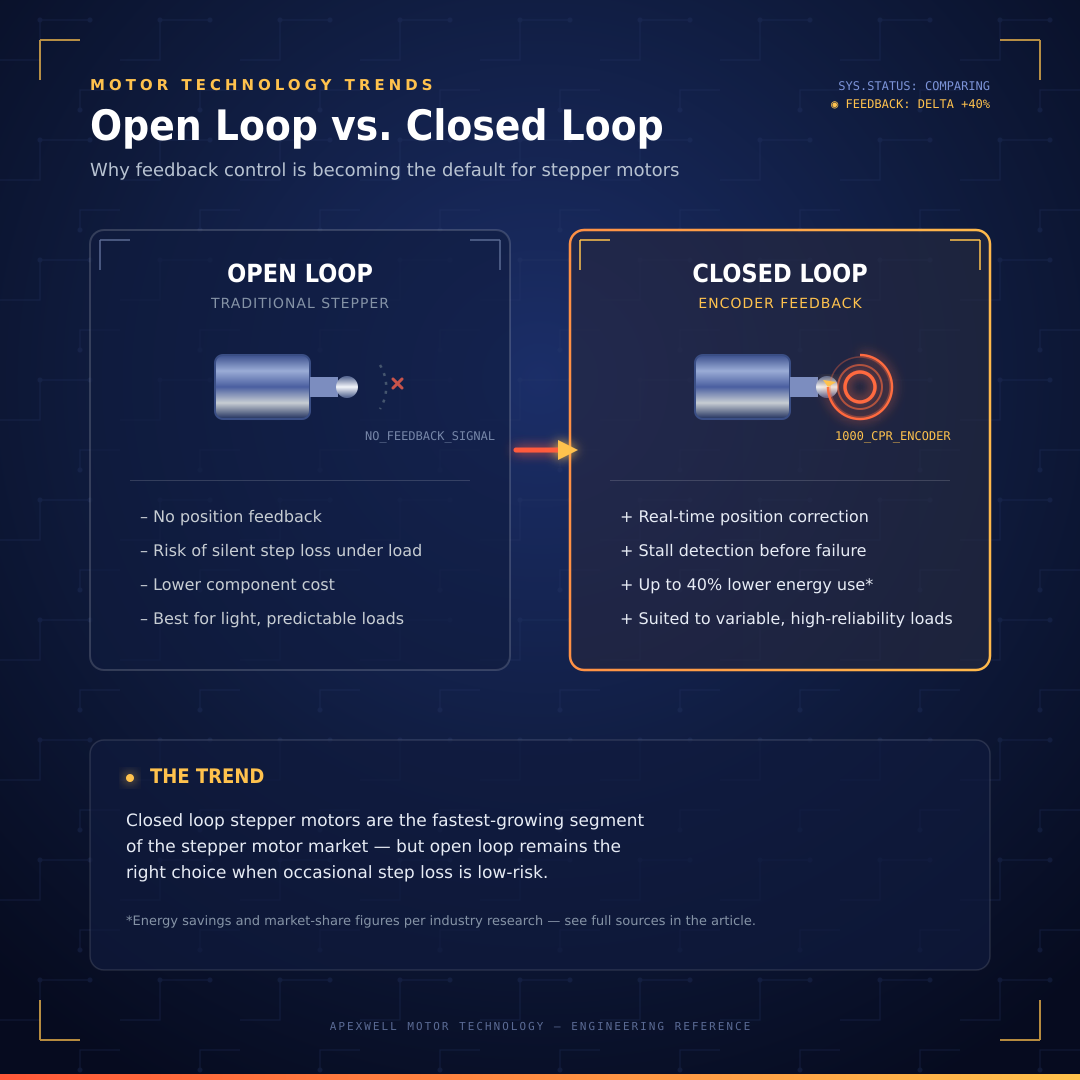
Every AW57HS motor integrates a 15-bit single-turn absolute magnetic encoder combined with an FOC (Field-Oriented Control) algorithm as standard, giving the built-in driver real-time visibility into actual rotor position rather than assuming commanded pulses were followed. Compliant with the CANopen standard servo communication protocol, the AW57HS supports position control, speed control, and homing (origin return) directly from the motor's integrated controller — see our article on why closed loop stepper motors are replacing traditional steppers for the broader trend behind this shift.
Typical Applications
With torque scaling from 0.55 N·m to 2.4 N·m in the NEMA 23 footprint, the AW57HS series fits industrial CNC axes, heavier robotic joints, conveyor and indexing drives, packaging machinery, and automated equipment where a panel-mount external driver isn't practical and closed loop feedback removes the risk of skipped steps under load.
Why Choose the AW57HS Series
The AW57HS folds the driver, absolute encoder, and FOC control loop into the motor housing itself, cutting cabinet space and wiring versus a motor-plus-external-driver setup. Multiple control methods — IO input, pulse/direction, PWM duty cycle, RS485 bus, and CAN bus — let the same motor slot into different control architectures without a hardware change. Built-in protection against overvoltage, undervoltage, overheating, and overcurrent keeps the driver safe under fault conditions, and a ready-to-use PC commissioning tool plus a dedicated CAN card and DLL shorten integration time. Custom shaft length, connector type, and encoder resolution are available on request.
We can customize the electrical parameters of the motor and geometric dimensions such as the motor output shaft size according to customer requirements. Accessories including pulleys, eccentric gearboxes, planetary gearboxes and encoders can also be added. For more products and detailed specifications, please download the product catalog from the Download Center.