Previous
Next
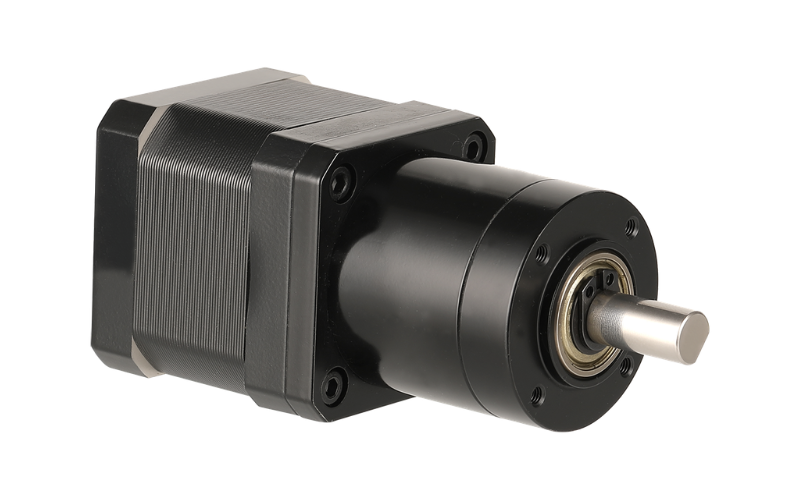
AW42HS Series — 42mm Stepper Motor with Planetary Gearbox
The AW42HS series pairs Apexwell's NEMA 17 (42mm), 1.8° hybrid stepper motor with an M36GXR planetary gearbox, offering motor holding torque from 0.10 N·m to 0.80 N·m and rated output torque up to 3.0 N·m after reduction. With four available gear-train stages and reduction ratios from 3.7:1 to 720:1 on the widely-used NEMA 17 footprint, this series sits above the AW28HS stepper-planetary line, for applications needing more output torque and higher shaft load capacity on a still-compact frame.
Shared Specifications (all models)
| Parameter | Value |
|---|---|
| Step Angle | 1.8° |
| Lead Wires | 4 (bipolar) |
| Gear Material | Metal (powder metallurgy) |
| Output Bearing | Ball bearings |
| Radial Play of Shaft | ≤0.05 mm |
| Thrust Play of Shaft | ≤0.3 mm |
| Max Radial Load | ≤8.0 kgf |
| Max Shaft Axial Load | ≤3.0 kgf |
| Backlash (no load) | ≤3° |
Motor Model Comparison
| Model | Body Length | Phase Current | Phase Resistance | Phase Inductance | Holding Torque | Rotor Inertia | Mass |
|---|---|---|---|---|---|---|---|
| AW42HS20-0804A | 20 mm | 0.8 A | 3.8 Ω | 4.5 mH | 0.10 N·m | 24 g·cm² | 0.12 kg |
| AW42HS28-0604A | 28 mm | 0.6 A | 8.0 Ω | 10.0 mH | 0.12 N·m | 30 g·cm² | 0.15 kg |
| AW42HS34-1304A | 34 mm | 1.3 A | 2.0 Ω | 2.8 mH | 0.28 N·m | 34 g·cm² | 0.22 kg |
| AW42HS40-1704A | 40 mm | 1.7 A | 2.2 Ω | 3.8 mH | 0.35 N·m | 54 g·cm² | 0.28 kg |
| AW42HS48-1704A | 48 mm | 1.7 A | 3.1 Ω | 5.0 mH | 0.52 N·m | 68 g·cm² | 0.35 kg |
| AW42HS60-1704A | 60 mm | 2.5 A | 1.25 Ω | 3.3 mH | 0.80 N·m | 80 g·cm² | 0.48 kg |
M36GXR Planetary Gearbox Specifications
| Parameter | 1-Stage | 2-Stage | 3-Stage | 4-Stage |
|---|---|---|---|---|
| Reduction Ratio | 3.7, 5.2 | 14, 19, 27 | 51, 71, 100, 139 | 189, 264, 369, 516, 720 |
| Gearbox Length (L1) | 31 mm | 40 mm | 49 mm | 58 mm |
| Rated Output Torque | 0.3 N·m | 1.2 N·m | 2.5 N·m | 3.0 N·m |
| Transmission Efficiency | 80% | 70% | 60% | 50% |
| Weight | 195 g | 210 g | 290 g | 330 g |
Momentary torque moment is rated at three times the rated allowable load across all four stages. The same 12 reduction ratios (3.7 to 720:1) used across Apexwell's stepper-planetary platform carry over to this frame size, now delivering up to 3.0 N·m of rated output torque.
Typical Applications
With output torque up to 3.0 N·m and reduction ratios up to 720:1 on the widely-used NEMA 17 footprint, the AW42HS series fits robotic arm joints, 3D printer and CNC feed axes, camera and gimbal positioning, automated valve and damper actuation, and general light-industrial equipment where a directly-driven NEMA 17 stepper doesn't have enough output torque or shaft load capacity.
Why Choose the AW42HS Gearmotor
Twelve reduction ratios across four gear-train stages let one motor selection be tuned across a wide speed/torque window without changing the mounting footprint. The ball-bearing output stage raises radial and axial load capacity well beyond what the bare motor shaft alone can support — up to 8.0 kgf radial and 3.0 kgf axial — while backlash stays within 3° at no load for repeatable positioning. Because the gearbox is factory-fitted and tested as a complete unit, output shaft alignment and gear mesh are verified before the motor ships. Custom shaft configurations and encoder feedback are available on request.
We can customize the electrical parameters of the motor and geometric dimensions such as the motor output shaft size according to customer requirements. Accessories including pulleys, eccentric gearboxes, planetary gearboxes and encoders can also be added. For more products and detailed specifications, please download the product catalog from the Download Center.