Previous
Next
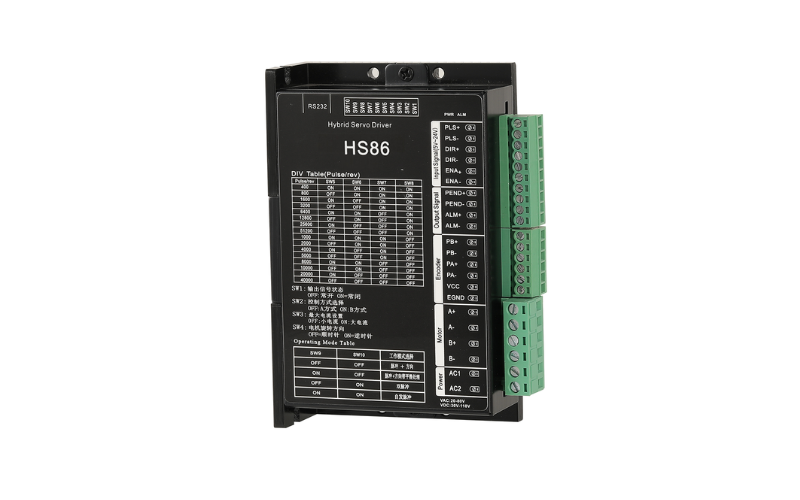
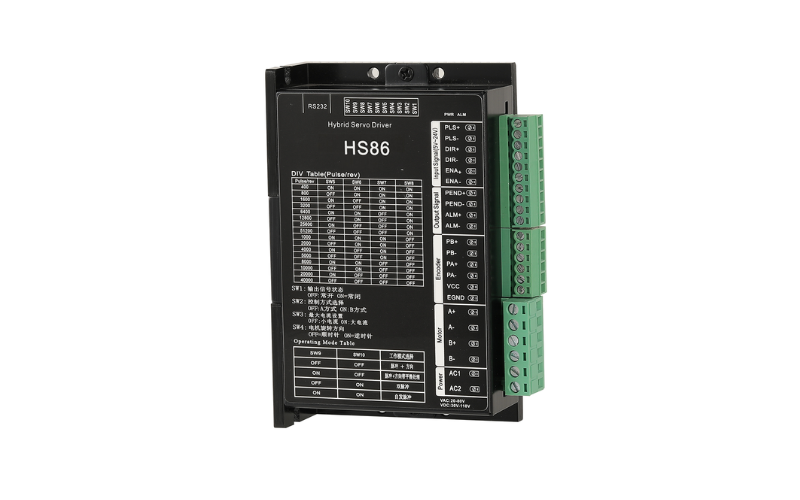
HS86 — Digital Hybrid Stepper Servo Driver
The Apexwell HS86 is a digital hybrid stepper servo driver featuring 32-bit DSP control technology, MODBUS-RTU communication, and PC-based serial debugging. It combines the control characteristics of open-loop stepper and servo systems to improve motion performance while reducing motor heating and low-speed vibration.
The HS86 supports a wide input power range, up to 200kHz pulse response frequency, and microstep settings from 200 to 40,000. Current, microstep resolution, and operating mode can be configured through the PC communication interface.
Key Features
Digital hybrid stepper servo driver
32-bit DSP control technology
MODBUS-RTU communication
PC-based serial parameter configuration
20–80VDC input power specification
Up to 200kHz pulse response frequency
200–40,000 microstep settings
External DIP switch for operating mode selection
Optically isolated differential signal inputs
Built-in microstep control
Precision current control
Reduced motor heating
Low vibration and low noise
Automatic current reduction at standstill
Overvoltage, undervoltage, and overcurrent protection
Encoder A/B signal input
Position-in-place and alarm outputs
Compact installation design
Shared Specifications
| Parameter | Specification |
|---|---|
| Product Type | Digital Hybrid Stepper Servo Driver |
| Control Technology | 32-bit DSP |
| Communication | MODBUS-RTU / RS232 |
| Input Power Voltage | DC 20–80V |
| Typical Input Voltage | DC 60V |
| Control Signal Input Current | 7–16mA |
| Typical Control Signal Current | 10mA |
| Pulse Frequency | 0–200kHz |
| Microstep Resolution | 200–40,000 |
| Cooling | Natural cooling / fan cooling |
| Operating Temperature | 0–50°C |
| Relative Humidity | 40–90% RH |
| Storage Temperature | -20 to +65°C |
| Insulation Resistance | 50MΩ |
Hybrid Stepper Servo Control
The HS86 uses a servo-like control principle while combining the characteristics of open-loop stepper and servo systems. According to the product documentation, this control approach is designed to improve stepper system performance, reduce motor heating and low-speed vibration, and provide fast start-stop response with low-vibration stopping.
The driver also supports automatic current reduction when the motor is stationary.
High-Resolution Microstep Control
The HS86 supports configurable microstep settings from 200 to 40,000 and a pulse response frequency of up to 200kHz. This provides flexible pulse-based motion control for systems requiring different microstep configurations and higher pulse input frequencies.
Control Signal Interface
The HS86 provides differential control inputs for pulse, direction, and enable functions.
PLS: Pulse control input
DIR: Direction control input
ENA: Enable control input
The PLS input supports +5V to +24V signals, with a pulse width requirement greater than 2μs for reliable response. The DIR input also supports +5V to +24V signals, while ENA is used to enable or disable motor operation.
Position and Alarm Outputs
The HS86 provides PEND and ALM output interfaces for system status monitoring.
PEND provides a position-in-place output when the motor reaches the commanded position.
ALM provides an alarm output when overcurrent, overvoltage, undervoltage, or position error conditions occur. Both outputs support a maximum drive current of 50mA.
Encoder Interface
The HS86 includes an encoder interface for A/B phase feedback and provides a 5V encoder power supply.
PA+ / PA-: Encoder A-phase input
PB+ / PB-: Encoder B-phase input
VCC: Encoder 5V power supply
EGND: Encoder power ground
Power and Motor Connections
The HS86 provides dedicated power and motor phase connections. The strong-current interface documentation specifies AC20–80V input or DC30–110V input, with dedicated A+ / A- and B+ / B- terminals for the two motor phases.
RS232 Serial Communication
The HS86 uses a PH2.0-7P connector for serial communication. A dedicated serial cable and USB-to-TTL conversion interface can be used to connect the driver to a PC for parameter configuration.
Through the PC software, users can configure parameters such as motor current, microstep resolution, and operating mode. The source documentation specifies that the serial connector must not be connected or disconnected while powered.
Protection Functions
The HS86 provides protection and alarm functions for common operating faults, including:
Overcurrent protection
Overvoltage protection
Undervoltage protection
Position error alarm
These functions provide additional monitoring for hybrid stepper motion control systems.
Environmental Conditions
The HS86 supports natural cooling or fan cooling and is specified for an operating temperature of 0–50°C and relative humidity of 40–90% RH.
The installation environment should avoid excessive dust, oil mist, corrosive gases, strong vibration, combustible gases, and conductive dust.
Typical Applications
The HS86 is designed for motion control systems using hybrid stepper motors where closed-loop-style control characteristics, encoder feedback, and flexible digital parameter configuration are required.
Typical applications include:
Industrial automation equipment
CNC and positioning systems
Linear motion equipment
Automated machinery
Precision positioning systems
OEM motion control equipment
Why Choose Apexwell HS86
The HS86 combines digital DSP control, hybrid stepper servo control, encoder feedback, high-resolution microstepping, and serial communication in a compact driver.
Its wide power input specification, 200kHz pulse response frequency, 200–40,000 microstep range, and PC-based parameter configuration provide flexible options for industrial and OEM motion control applications.
For application-specific requirements, contact Apexwell to discuss compatible hybrid stepper motors, driver settings, and motion system configuration.