Previous
Next
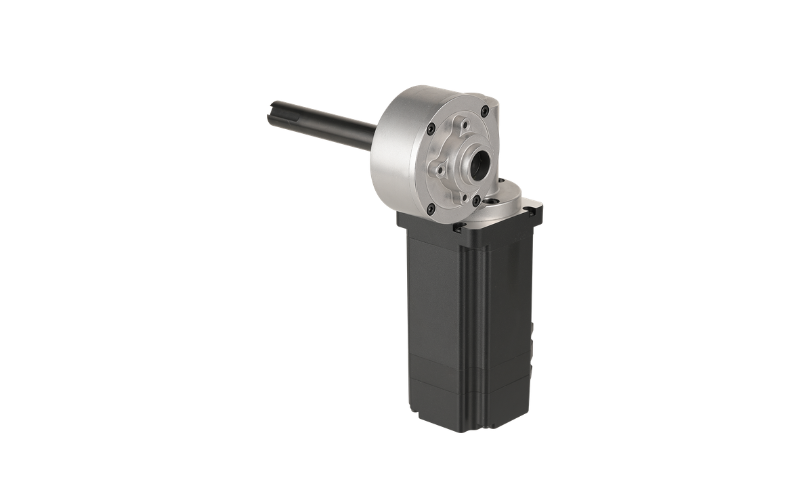
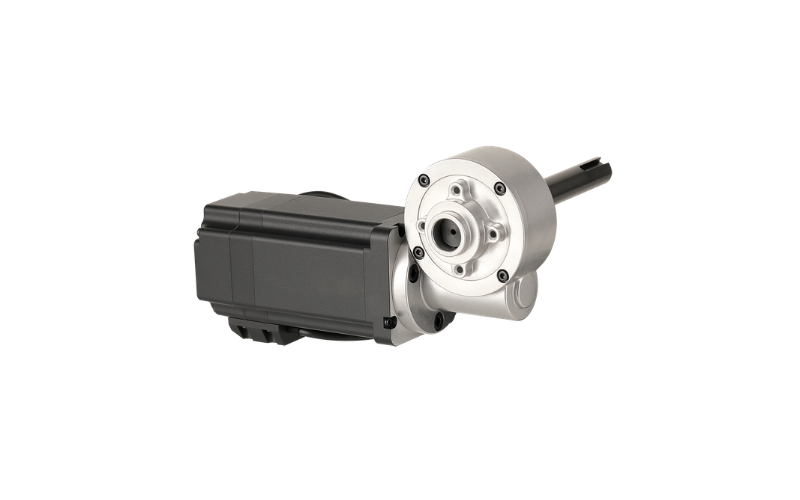
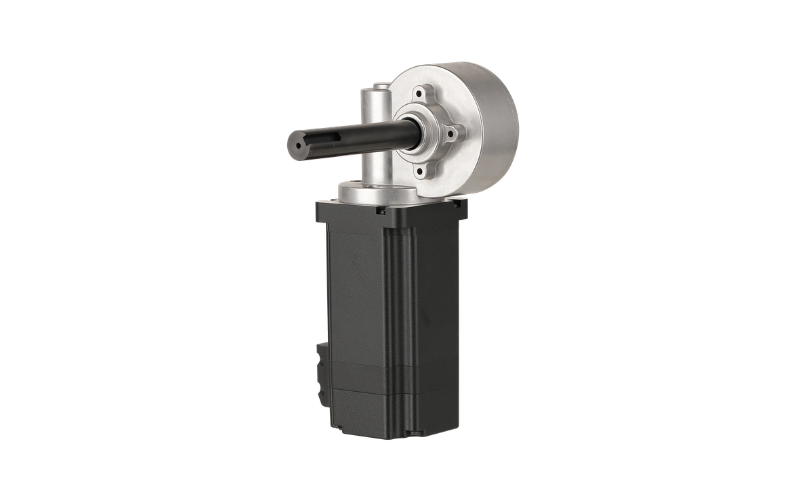
AW86BLF Series — 86mm BLDC Motor with Worm Reduction Gearbox
The AW86BLF series pairs Apexwell's 86mm-diameter, 48V brushless DC motor with an NMRV040 worm reduction gearbox, scaling rated output power from 130W to 500W across body length. The gearbox platform is shared with the AW60BLF worm-gear series — same reduction ratios, same 40 N·m maximum permissible torque — so this line delivers the same gearbox output from a higher-torque motor stack.
Shared Motor Specifications (all models)
| Parameter | Value |
|---|---|
| Winding Configuration | Star (Y) |
| Hall Sensor Position | 120° |
| Insulation Class | Class B |
| Ambient Temperature | -20°C to +50°C |
| Insulation Resistance | ≥100 MΩ (500 VDC) |
| Dielectric Strength | 700 VAC, 1 minute |
| Number of Poles | 4 |
| Number of Phases | 3 |
| Nominal Voltage | 48 VDC |
| Rated Speed | 3,000 RPM ±10% |
Motor Model Comparison
| Model | Rated Torque | Rated Current | Output Power | Peak Torque | Peak Current | Body Length | Mass |
|---|---|---|---|---|---|---|---|
| AW86BLF75-430 | 0.41 N·m | 3.7 A | 130 W | 1.23 N·m | 11.1 A | 75 mm | 1.5 kg |
| AW86BLF90-430 | 0.80 N·m | 6.8 A | 250 W | 2.40 N·m | 20.4 A | 90 mm | 2.0 kg |
| AW86BLF105-430 | 1.30 N·m | 11.3 A | 400 W | 3.90 N·m | 33.9 A | 105 mm | 2.5 kg |
| AW86BLF115-430 | 1.70 N·m | 14.5 A | 500 W | 5.10 N·m | 43.5 A | 115 mm | 3.0 kg |
| AW86BLF145-430 | 1.70 N·m | 14.5 A | 500 W | 5.10 N·m | 43.5 A | 145 mm | 3.0 kg |
Torque constant ranges from 0.108 to 0.117 N·m/A; back-EMF constant ranges from 8.38 to 9.66 Vrms/kRPM. Rotor inertia scales from 0.81 to 2.14 kg·cm² with body length.
NMRV040 Worm Reduction Gearbox Specifications
| Parameter | Value |
|---|---|
| Reduction Ratio | 7.5, 10, 15, 20, 25, 30, 40, 50, 60, 80, 100 |
| Gearbox Length (L1) | 120 mm |
| Max Torque Moment | 40 N·m |
| Transmission Efficiency | 60% |
| Weight | 2.3 kg |
Eleven reduction ratios are available (7.5 to 100:1) on a fixed gearbox footprint — identical to the NMRV040 used on the AW60BLF, since both series share the same gearbox platform.
Wiring
Each AW86BLF motor exits with a 3-core sheathed power cable for the U/V/W windings and a separate 5-core shielded Hall sensor cable (+5VDC, GND, HU, HV, HW) at a 120° Hall electrical angle for standard 6-step commutation.
Typical Applications
With a right-angle output and torque up to 5.1 N·m at the motor and 40 N·m at the gearbox, the AW86BLF worm-gear series fits heavy industrial gate and door actuators, large valve and damper drives, lift and tilt mechanisms, and other applications where the AW60BLF's motor torque isn't enough but the same gearbox output range fits the load.
Why Choose the AW86BLF Worm Gearmotor
The right-angle output lets the gearbox change direction in the mechanical layout without an additional bevel or belt stage, and worm gearing at higher reduction ratios typically resists being back-driven by the load — useful in lifting, tilting, or holding applications where position needs to stay put if power is lost. Because the gearbox platform is shared with the AW60BLF, a design can move between the two motor frames without changing gearbox dimensions or ratio options. Custom shaft configurations and encoder feedback are available on request.
We can customize the electrical parameters of the motor and geometric dimensions such as the motor output shaft size according to customer requirements. Accessories including pulleys, eccentric gearboxes, planetary gearboxes and encoders can also be added. For more products and detailed specifications, please download the product catalog from the Download Center.